Research
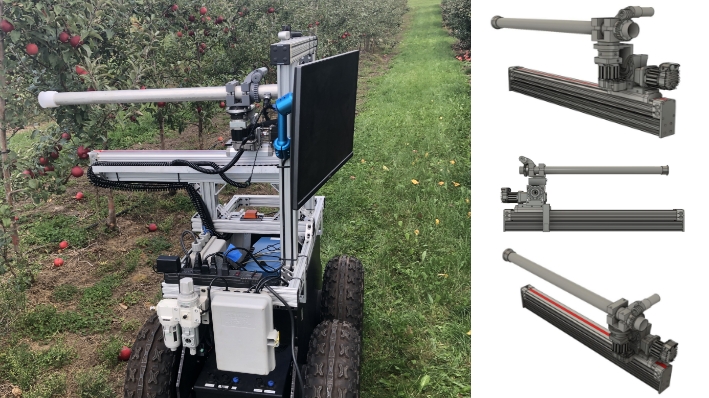
Agricultural Robotic Systems for Efficient Apple Harvesting
Selected Publications
Development and Evaluation of a Dual-Arm Robotic Apple Harvesting System
Computers and Electronics in Agriculture, 2024
An Automated Apple Harvesting Robot – From System Design to Field Evaluation
Journal of Field Robotics, 2024
Algorithm Design and Integration for a Robotic Apple Harvesting System
IEEE/RSJ International Conference on Intelligent Robots and Systems, 2022
Efficient Data-Enabled Predictive Control for Autonomous Systems
Selected Publications
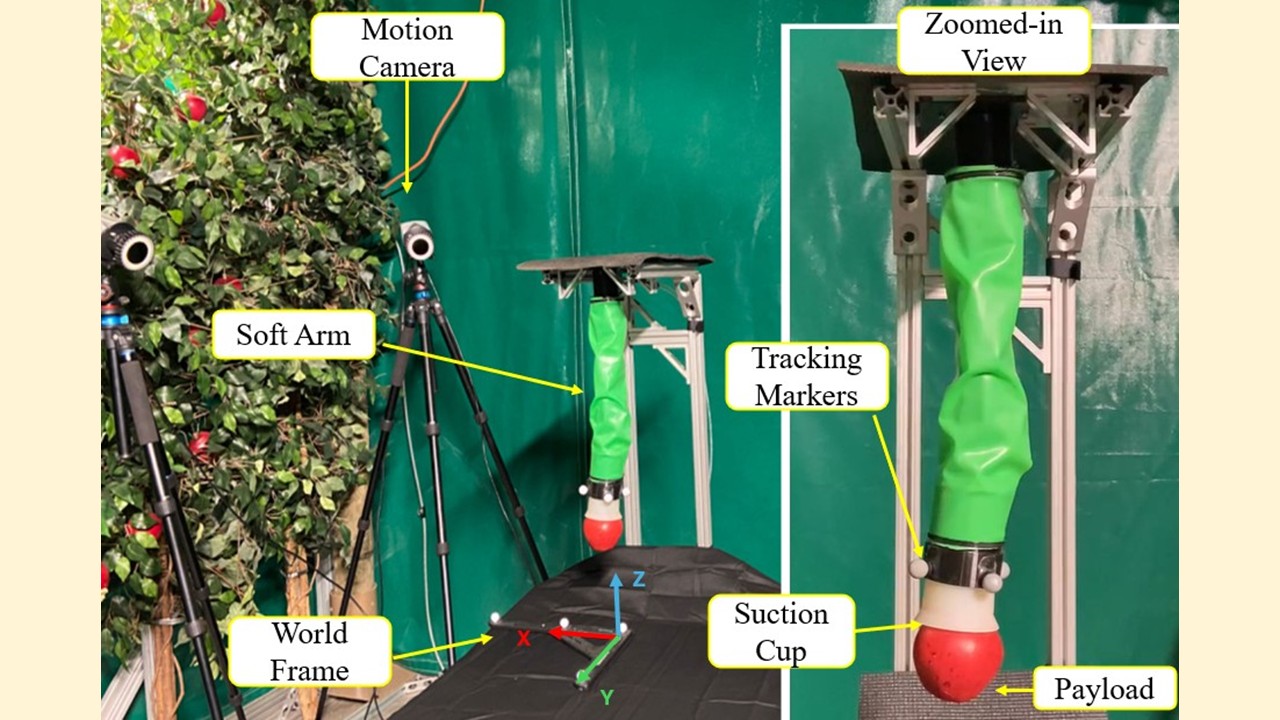
Velocity-Form Data-Enabled Predictive Control of Soft Robots Under Unknown External Payloads
IEEE Robotics and Automation Letters, 2026
Data-Enabled Neighboring Extremal: Case Study on Model-Free Trajectory Tracking for Robotic Arm
IEEE Transactions on Control Systems Technology, 2026
Mechanical Design and Data-Enabled Predictive Control of a Planar Soft Robot
IEEE Robotics and Automation Letters, 2024
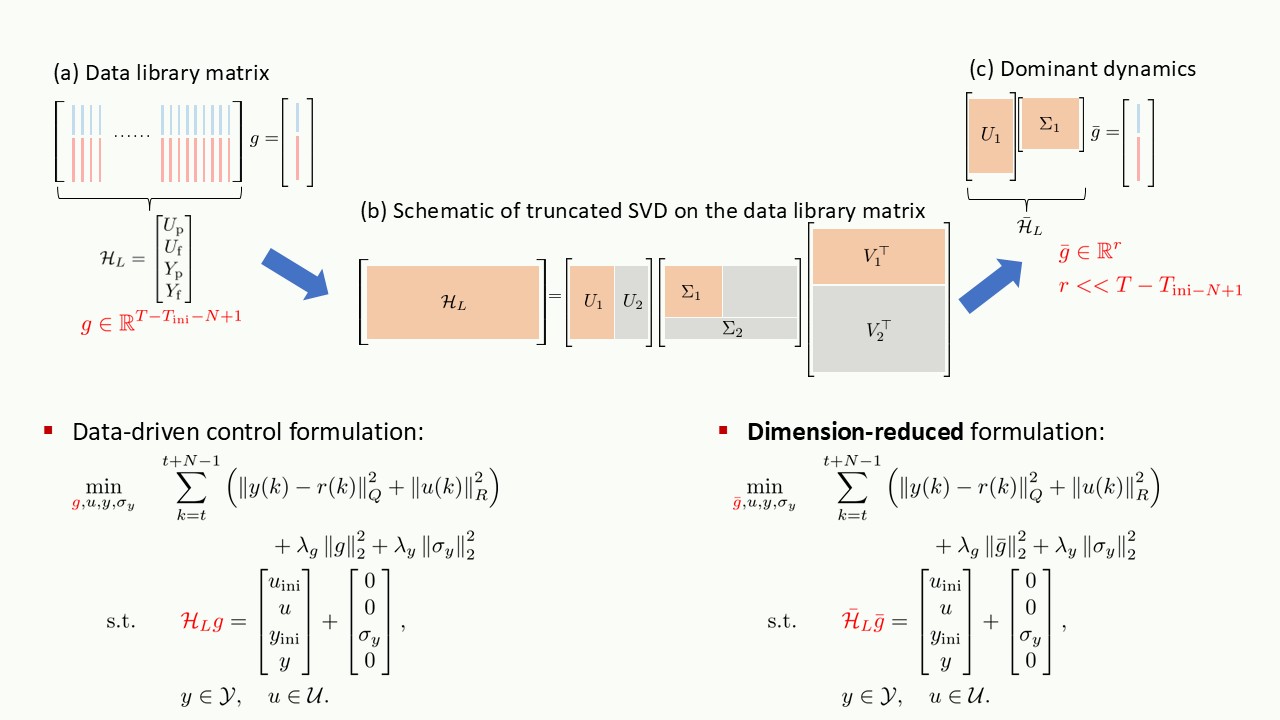
Dimension Reduction for Efficient Data-Enabled Predictive Control
IEEE Control Systems Letters, 2023
Cloud/Distributed Control for Privacy-Critical Systems
Selected Publications
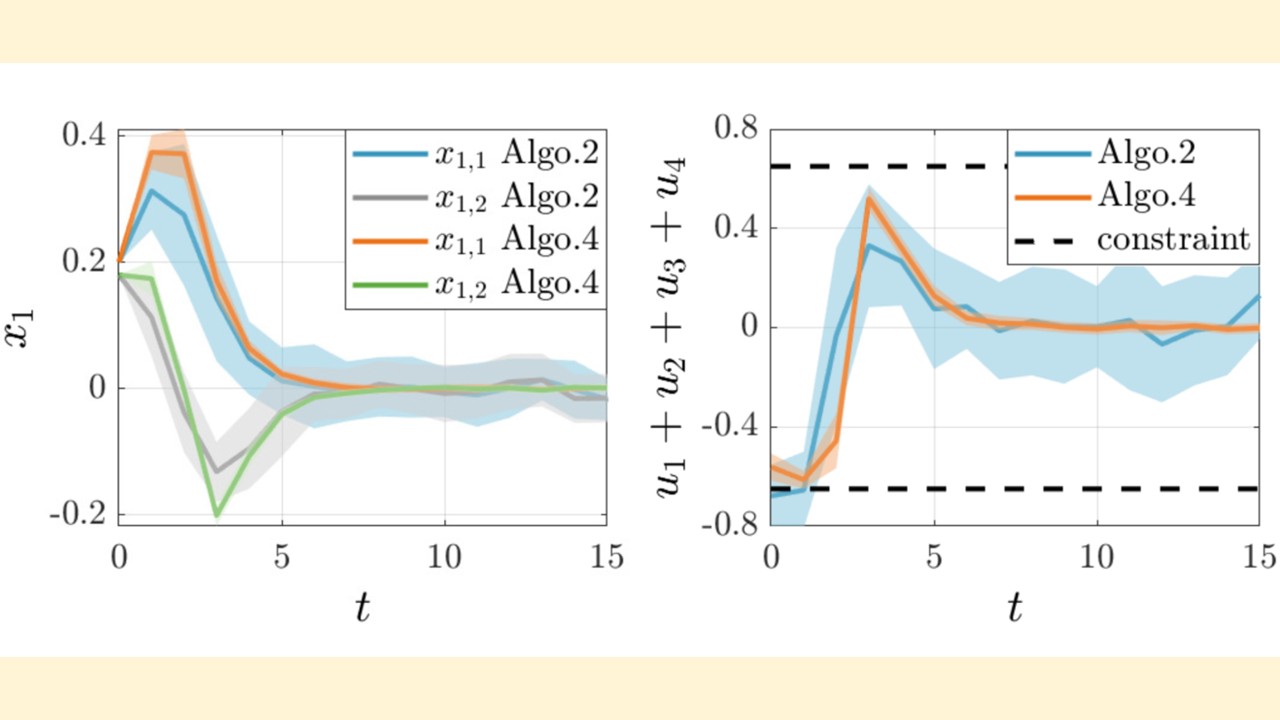
Differentially-Private Distributed Model Predictive Control of Linear Discrete-Time Systems with Global Constraints
IEEE Transactions on Automatic Control, 2026
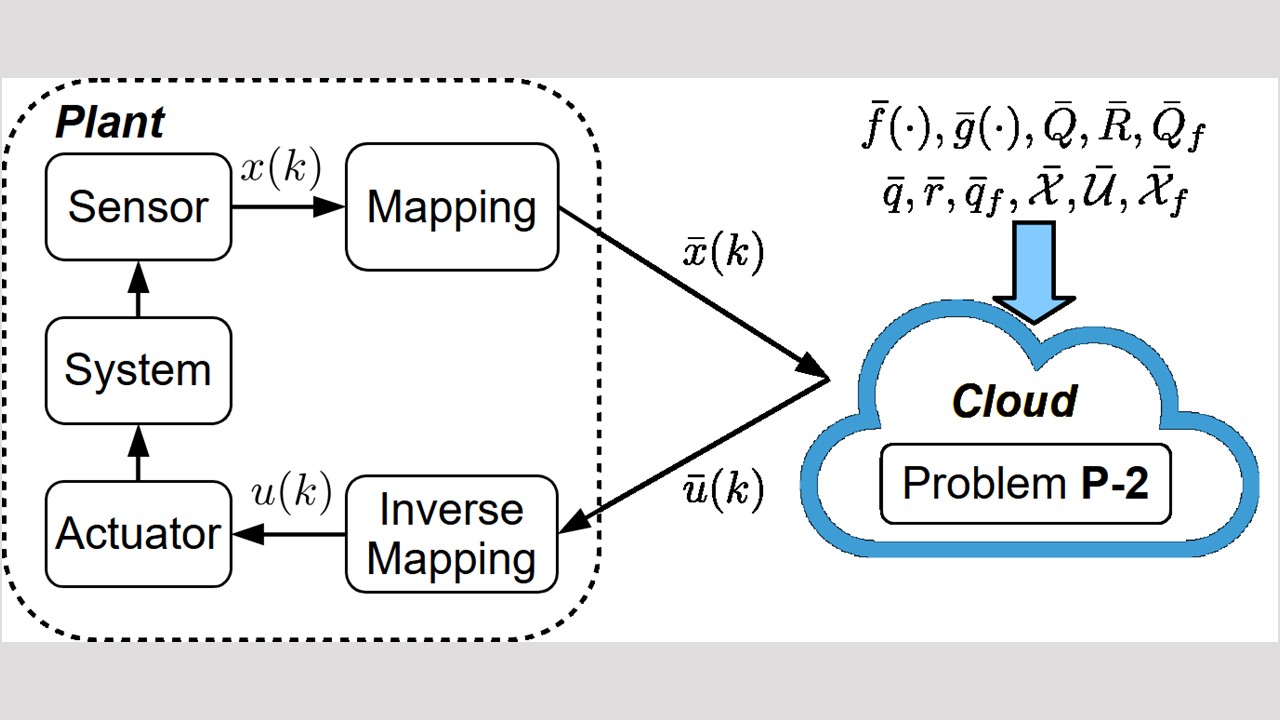
Privacy-Preserving Nonlinear Cloud-Based Model Predictive Control via Affine Masking
Automatica, 2025
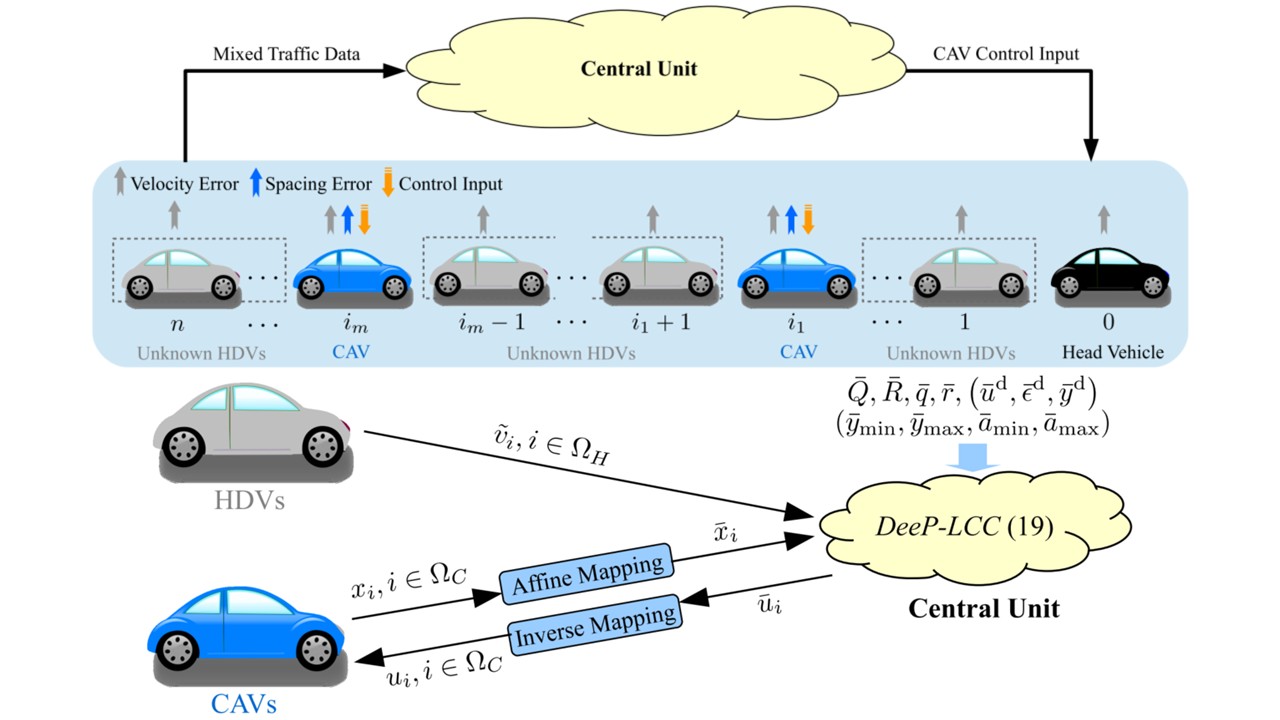
Privacy-Preserving Data-Enabled Predictive Leading Cruise Control in Mixed Traffic
IEEE Transactions on Intelligent Transportation Systems, 2024
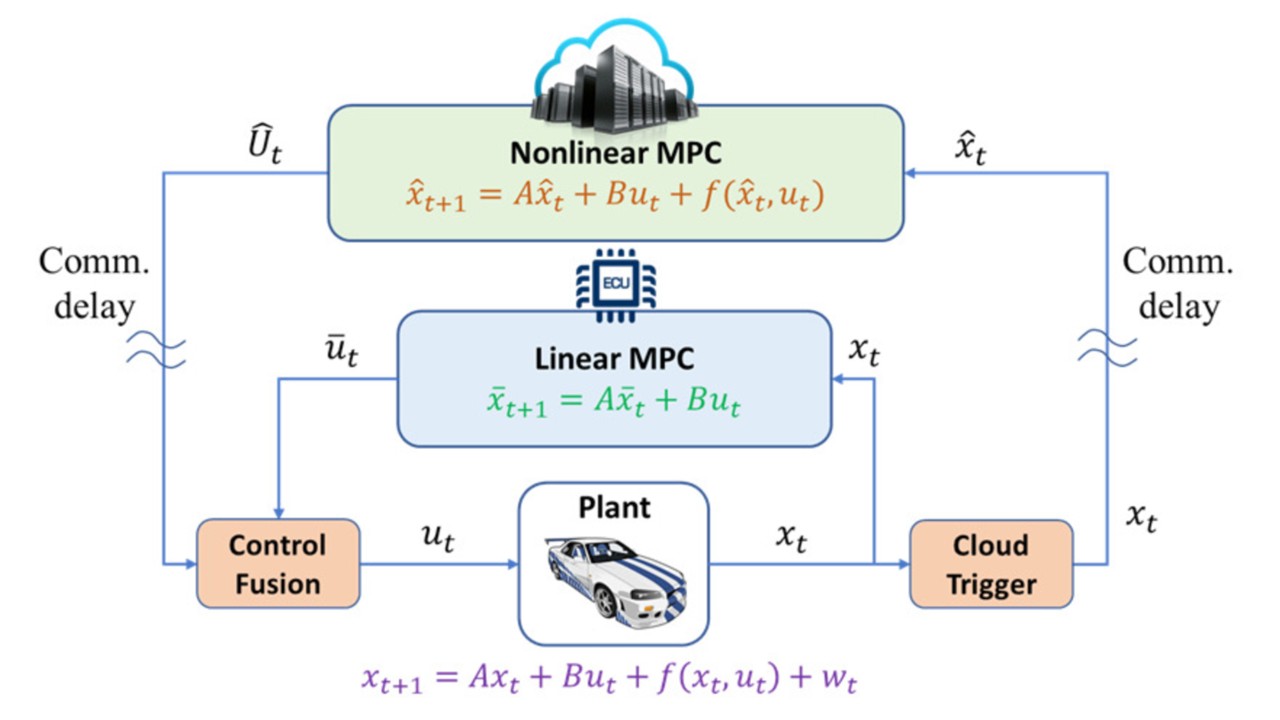
Cloud-Assisted Nonlinear Model Predictive Control for Finite-Duration Tasks
IEEE Transactions on Automatic Control, 2023
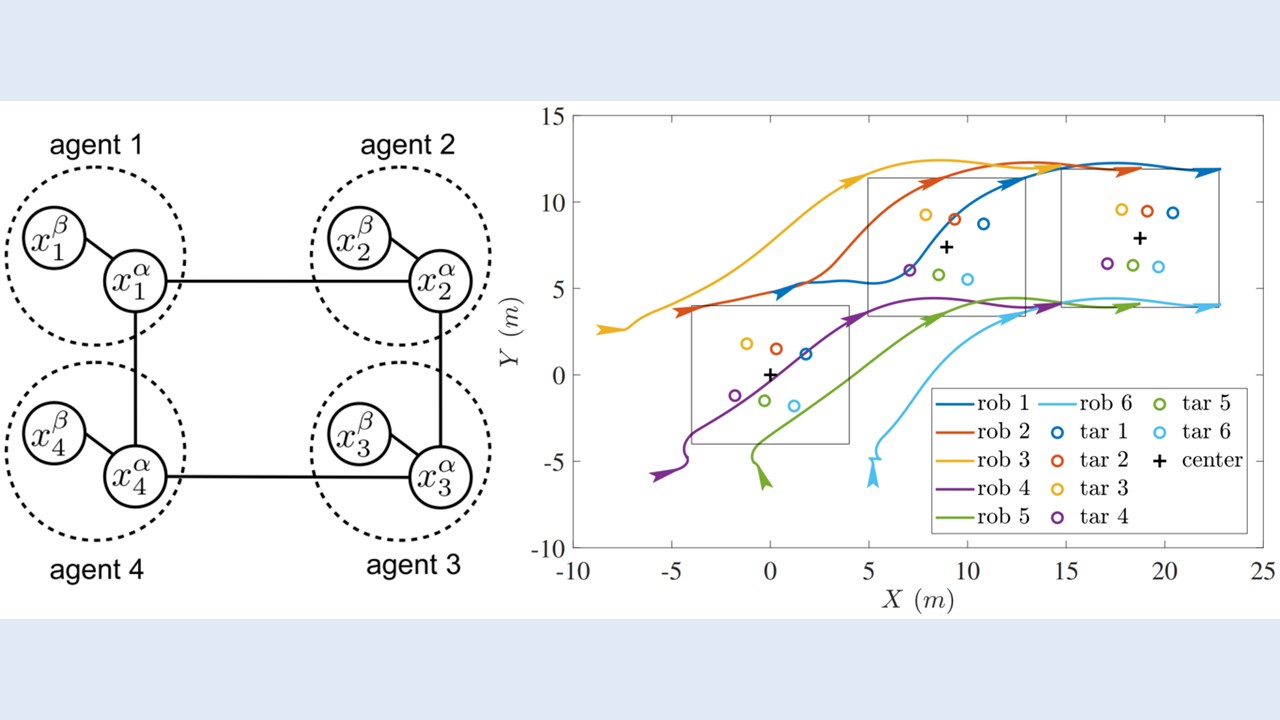
Privacy-Preserving Dynamic Average Consensus via State Decomposition: Case Study on Multi-Robot Formation Control
Automatica, 2022
Machine Vision-Based Robotic Control With Guaranteed Stability
Selected Publications
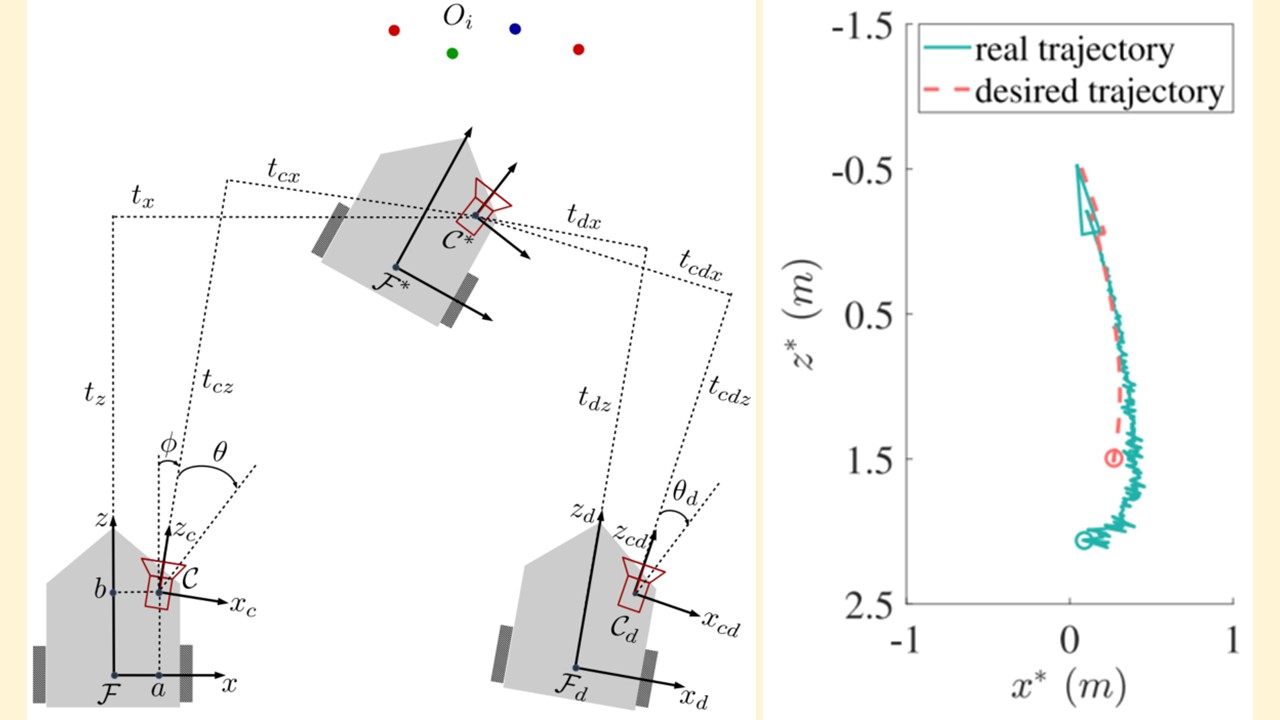
Visual Trajectory Tracking of Wheeled Mobile Robots With Uncalibrated Camera Extrinsic Parameters
IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2021
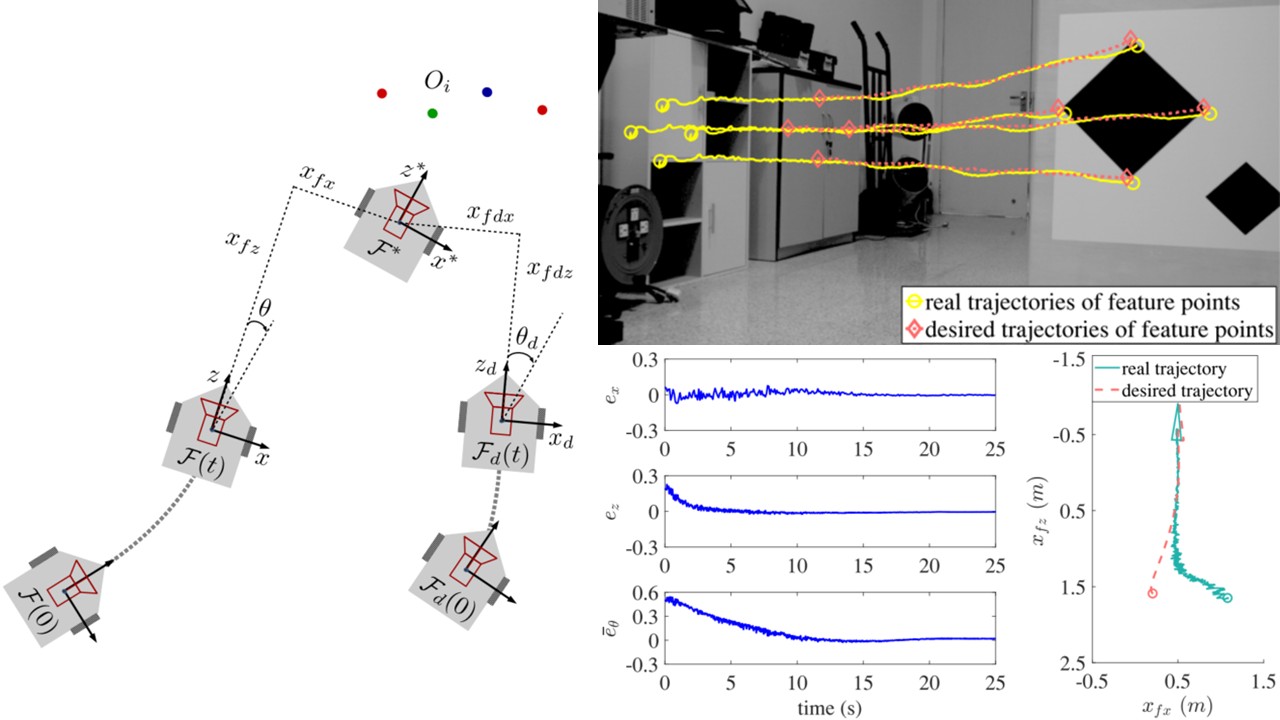
Visual Tracking and Depth Estimation of Mobile Robots Without Desired Velocity Information
IEEE Transactions on Cybernetics, 2020
Trifocal Tensor-Based 6 DOF Visual Servoing
International Journal of Robotics Research, 2019
Unified Visual Servoing Tracking and Regulation of Wheeled Mobile Robots With an Uncalibrated Camera
IEEE/ASME Transactions on Mechatronics, 2018
Trifocal Tensor-Based Adaptive Visual Trajectory Tracking Control of Mobile Robots
IEEE Transactions on Cybernetics, 2017